Motion Planning Libraries
Ongoing
TL;DR CPU motion planning in milliseconds on OMPL and VAMP, with one pip-installable stack per robot and a shared Python API. Stacks marked FLASK add kinodynamic planning.
Uniform Framework for Data Gathering and Behavior Cloning
Completed
TL;DR One imitation-learning framework across many teleoperation interfaces and robots, from collecting demonstrations to training ACT and diffusion policies.
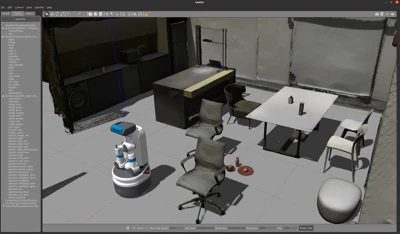
Digital Twin and 3D Reconstruction
Completed
TL;DR Gaussian Splatting tools for indoor 3D mesh reconstruction, and a digital twin of the lab built on them for CS6244 projects and mobile manipulation research.