Publication

Agent Priors-guided Policy Learning
In Submission
Puming Jiang*, Tianrun Hu*, Haozhe Du, Yibo Li, Zhiwei Xue, Xinhu Li, Harold Soh
TL;DR A policy's structural prior is its interface to the agent. It helps the policy generalize and tells the agent where the skill works.
Receding-Horizon Pushing with Composable Object-Centric Policies
In Submission
Zhiyi Yuan*, Tianrun Hu, Anxing Xiao, Yuhong Deng, David Hsu, Hanbo Zhang
TL;DR A high-level planner splits a long push into short subgoals, and a learned object-centric policy pushes the object to each one.
Visibility-Aware Mobile Grasping in Dynamic Environments
RSS 2026 Workshop (ExWBC) · Oral Presentation
Tianrun Hu*, Anxing Xiao, David Hsu, Hanbo Zhang
TL;DR In a dynamically changing environment, a moving robot must see both the obstacles in its way and the object it wants to grasp. We balance the two.
Uncertainty Estimation for Visual Grounding in the Open World
In Submission
Hanbo Zhang*, Tianrun Hu, Cedar Site Bai, Anxing Xiao, David Hsu
TL;DR Calibrated uncertainty for open-world visual grounding, so planning knows what perception does not know.
Hypothesis-driven Model Expansion under Uncertainty for Open-World Robot Planning
Robotics: Science and Systems (RSS) 2026
Anxing Xiao*, Hanbo Zhang, Tianrun Hu, David Hsu
TL;DR In the open world, foundation models propose hypotheses, the robot verifies them while doing the task, and it expands its world model with what it learns.
Chain-of-Action: Trajectory Autoregressive Modeling for Robotic Manipulation
Conference on Neural Information Processing Systems (NeurIPS) 2025
Wenbo Zhang*, Tianrun Hu, Yanyuan Qiao, Hanbo Zhang, Yuchu Qin, Yang Li, Jiajun Liu, Tao Kong, Lingqiao Liu†, Xiao Ma†
TL;DR The policy predicts the goal action first, then builds the trajectory backward from it.
MimicFunc: Imitating Tool Manipulation from a Single Human Video via Functional Correspondence
Conference on Robot Learning (CoRL) 2025
Chao Tang*, Anxing Xiao, Yuhong Deng, Hu Tianrun, Wenlong Dong, Hanbo Zhang, David Hsu, and Hong Zhang
TL;DR Functional correspondence lets the robot learn tool use from one human video and apply it to new tools that look different but do the same job.
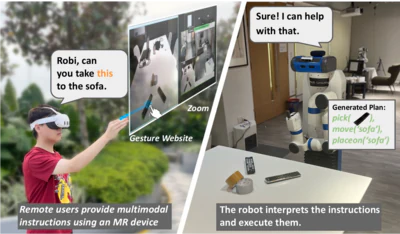
Robi Butler System
Robi Butler: Remote Multimodal Interactions with Household Robot Assistant
IEEE International Conference on Robotics and Automation (ICRA) 2025
Anxing Xiao*, Nuwan Janaka, Hu Tianrun, Anshul Gupta, Kaixin Li, Cunjun Yu, David Hsu
TL;DR Control a household robot over a video call with voice, text, and pointing.
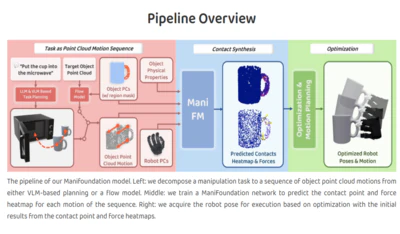
ManiFoundation Model System
ManiFoundation Model for General-Purpose Robotic Manipulation of Contact Synthesis with Arbitrary Objects and Robots
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2024
Zhixuan Xu*, Chongkai Gao*, Zixuan Liu*, Gang Yang*, Chenrui Tie, Haozhuo Zheng, Haoyu Zhou, Weikun Peng, Debang Wang, Hu Tianrun, Tianyi Chen, Zhouliang Yu, Lin Shao
TL;DR One model for any object and robot, predicting where to touch and what force or motion to apply.